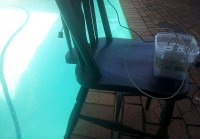
Success with the Ultrasonic sensor works fine with water and wasn't put off with splashing. Now I am waiting for a new gyro/gravity/magnetic heading sensor the one I had was for another computer model so I ordered one for the Pi Zero I am using, should get that tomorrow then I will hook up to the servos and test again.
I don't think I need a level sensor anyway, the gyro magnetometer is so sensitive, it will be able to detect the acceleration upwards and downwards which is what you should use rather than distance above water, I will just use the ultrasonic as a reference.
I don't think I need a level sensor anyway, the gyro magnetometer is so sensitive, it will be able to detect the acceleration upwards and downwards which is what you should use rather than distance above water, I will just use the ultrasonic as a reference.